2025 - 2026

Design of Compound Die and Measurement of Burr Heights Using Theoretical and Simulation Approach

Project academic year
Abstract
This project investigates the design of the compound die and measures the burr heights using theoretical and numerical methodologies. The main aim of the project is to obtain the optimum design of the compound die with its cutting tools and to improve the cutting quality of ferrous products. The model of the compound die is designed using standard mathematical equations. It is used to produce an exhaust gas recirculation plate. Finite element technique (ANSYS software) has been used to achieve the research objectives. ANSYS is used to simulate the cutting operation and to analyze the sheet material deformation (burr heights). The final results indicate that the proposed design of the compound die can provide a clean cutting surface of the product under minimum burr height and implement the double cutting operation using the developed compound die without failure. The current project provides a better prediction of burr heights and efficient use of compound dies. The outcome indicates that the burr heights of the final product are at a smaller size for ferrous sheet materials. The findings provide optimum design and developed models of the compound die, improved product quality, and the lowest burr heights.
Keywords
Compound Die
Burr Height
Sheet Metal Blanking
Finite Element Analysis (ANSYS)
Cutting Clearance

Smart Food Recognition and Nutrition estimation based on learning approaches.

Project academic year
Abstract
The proposed Smart Food Recognition and Nutrition Estimation System introduces an AI-driven approach for automated food analysis and nutritional assessment. A) Ingredient Segmentation: Rather than relying on image-level food classification, the system employs semantic segmentation to identify and separate multiple food ingredients within a single meal image at the pixel level. B) Multi-Scale Feature Extraction: An Encoder - Decoder architecture is enhanced with a deep backbone network and an Atrous Spatial Pyramid Pooling (ASPP) module to capture food ingredients of different sizes and spatial characteristics. C) Attention-Based Feature Enhancement: Squeeze-and-Excitation (SE) blocks and Global Pyramid Attention (GPA) modules are integrated to emphasize important features and improve segmentation quality. D) Automated Nutrition Estimation: After ingredient recognition, the detected classes are matched with nutritional records obtained from the USDA FoodData Central database to estimate calories, proteins, carbohydra
Keywords
Deep Learning

Enhancing Communication Reliability in High – Speed Train Networks Using Intelligent Reflecting Surfaces (IRS)

Project academic year
Abstract
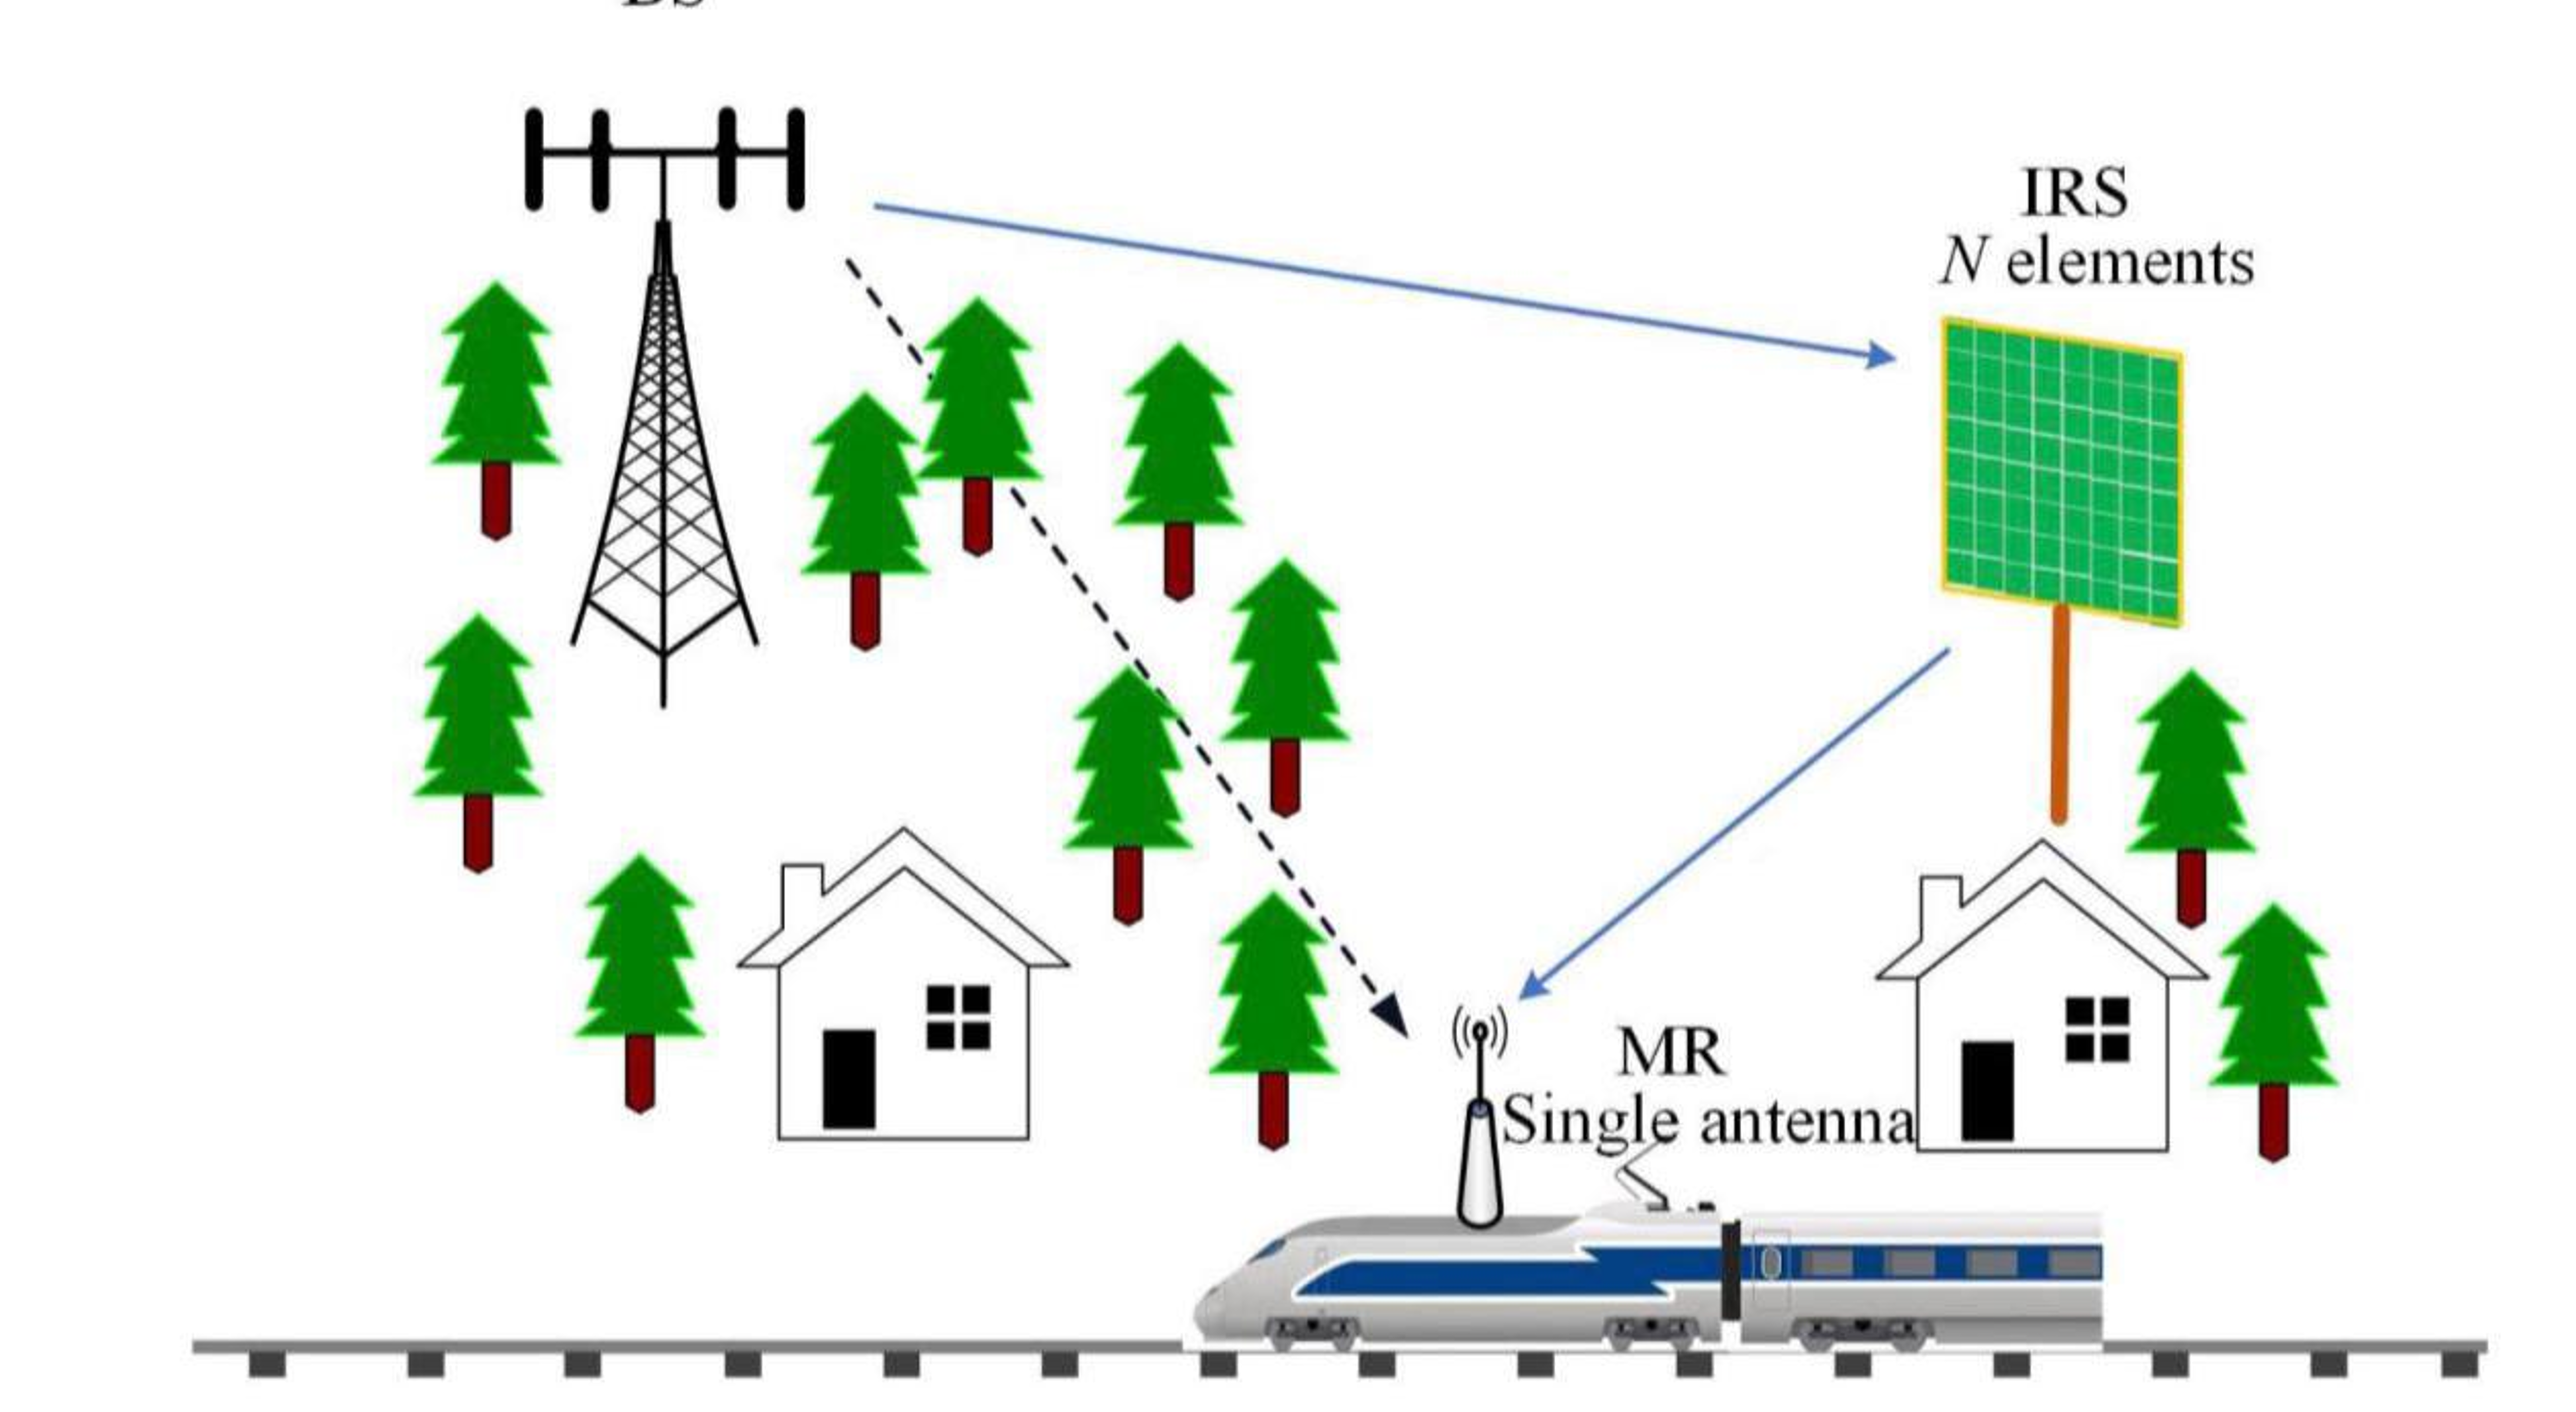
High-speed train (HST) networks experience severe communication reliability degradation due to extreme mobility, rapid time-varying channels, severe Doppler shifts, and frequent signal blockages caused by railway infrastructure. To overcome these critical propagation barriers, this graduation project investigates the utilization of Passive Intelligent Reflecting Surfaces (IRS) to dynamically reconfigure the wireless environment and enhance link reliability. A comprehensive multi-user wireless communication system is proposed, featuring a Base Station (BS) equipped with eight transmitting antennas (S = 8) serving two groups of users organized into distinct clusters, with each user utilizing eight receiving antennas (P = 8). To optimize spectral and energy efficiency, Non-Orthogonal Multiple Access (NOMA) is implemented with three users per sub-band using a 16-QAM digital modulation scheme. The wireless links involving the IRS are thoroughly modeled under a Rician channel distribution to evaluate both Line-of-S
Keywords
IRS; NOMA; HST
Project Poster
IRS wireless communication system

Design and Implementation of Pick and Place SCARA robot

Project academic year
Abstract
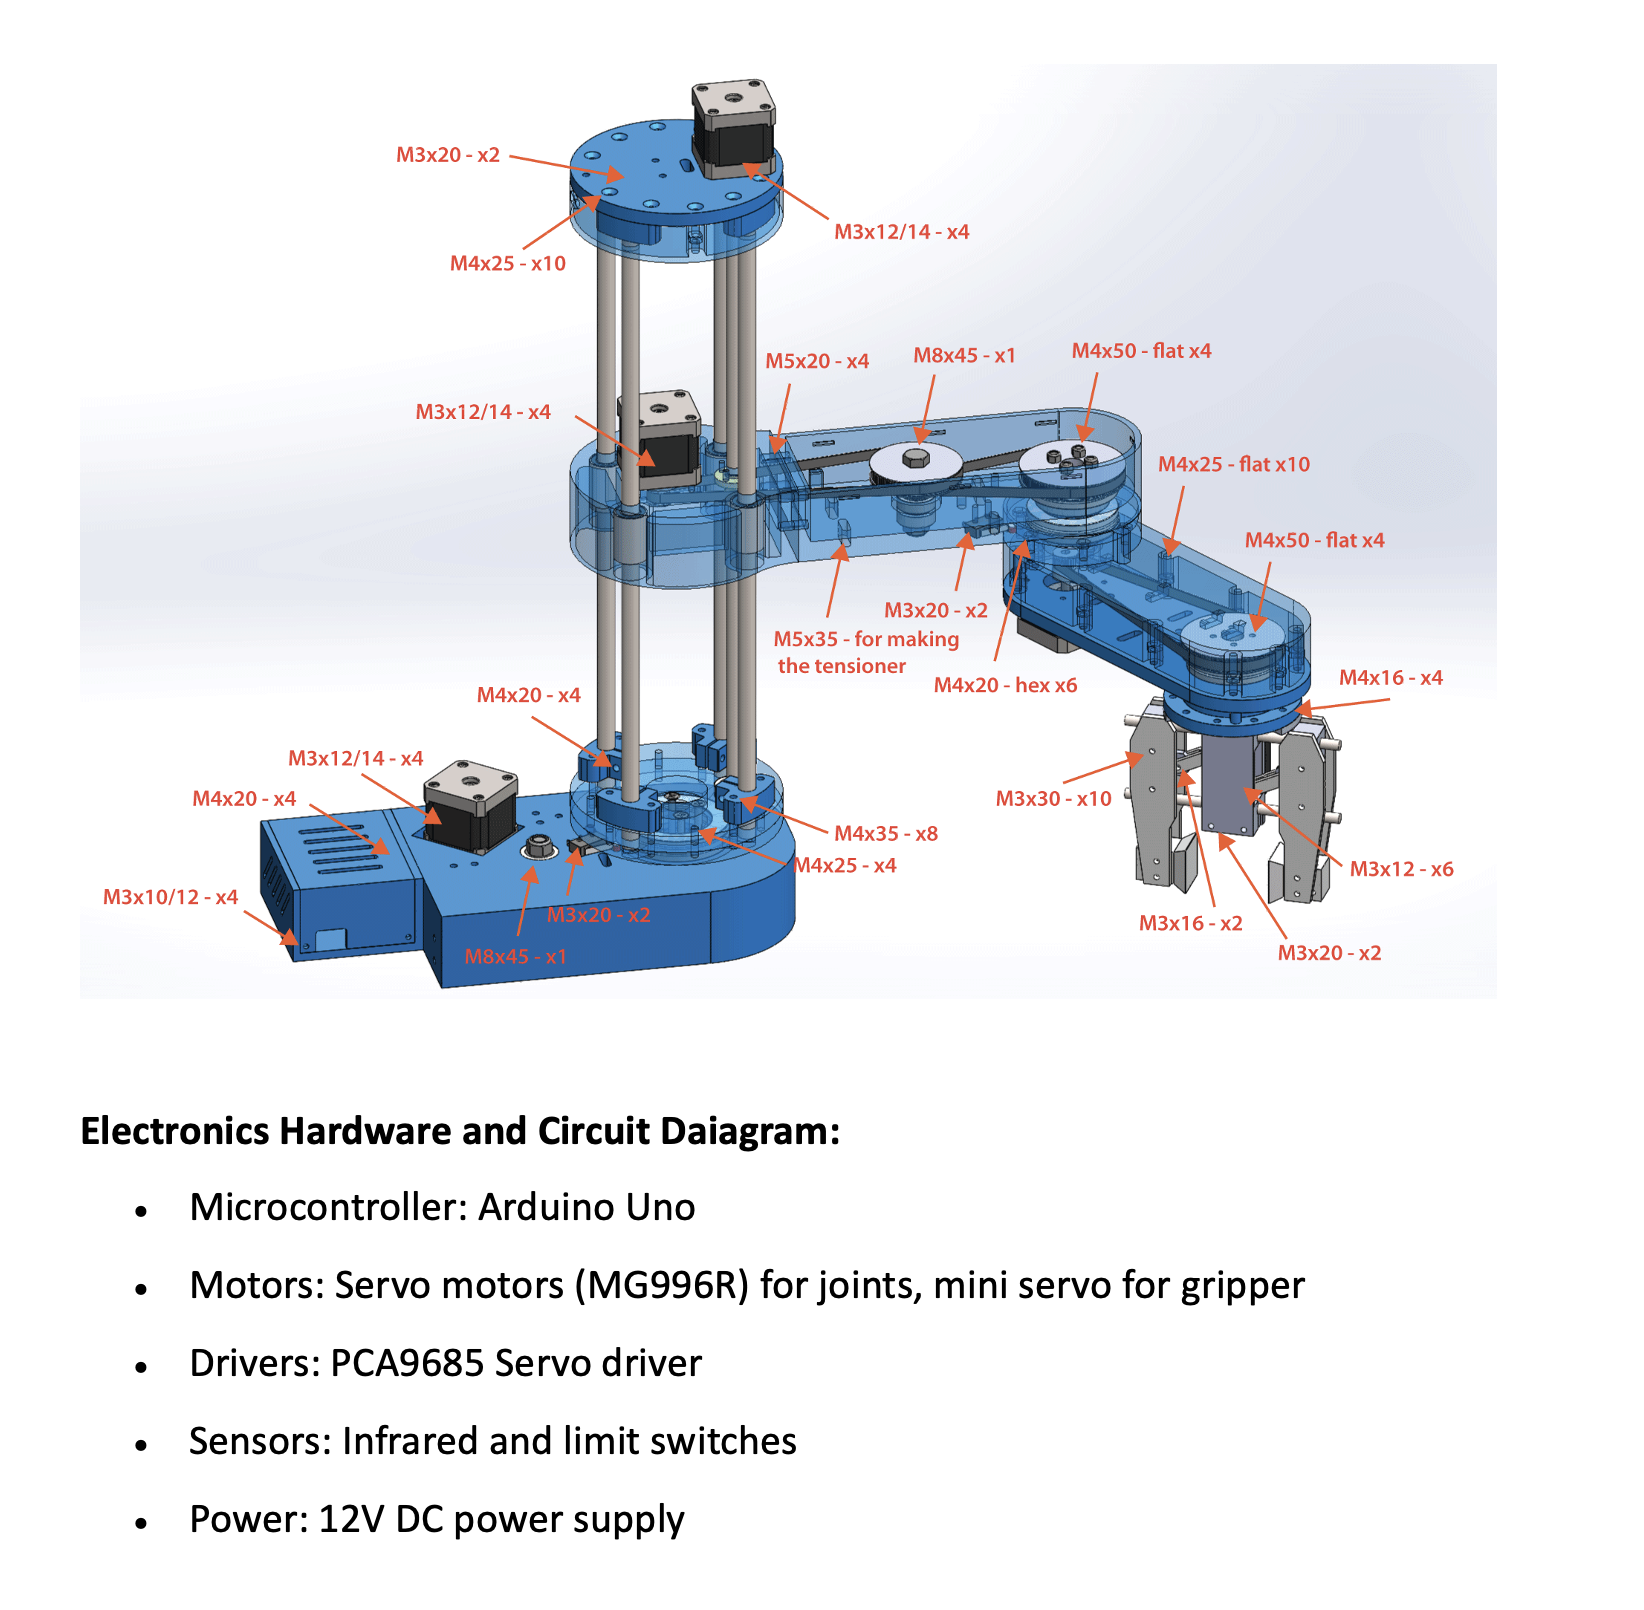
This project presents the design and implementation of a Selective Compliance Assembly Robot Arm (SCARA) optimized for automated pick-and-place operations. Featuring two horizontal revolute joints and a vertical prismatic axis, the manipulator achieves high precision, fast cycle times, and structural rigidity within a defined workspace. Microcontroller-based hardware integrates stepper motors, feedback encoders, and an end-effector gripper, while custom kinematic algorithms drive precise trajectory planning. Experimental testing confirms high repeatability, position accuracy, and efficient payload handling. The implemented SCARA system offers a scalable, cost-effective solution for industrial automation, streamlining tasks like component sorting, assembly line transfer, and automated packaging.
Keywords
SCARA robot
Arduino
raspberry PI
Project Poster
Design and Implementation of Pick and Place SCARA robot