Department
Project academic year
Abstract
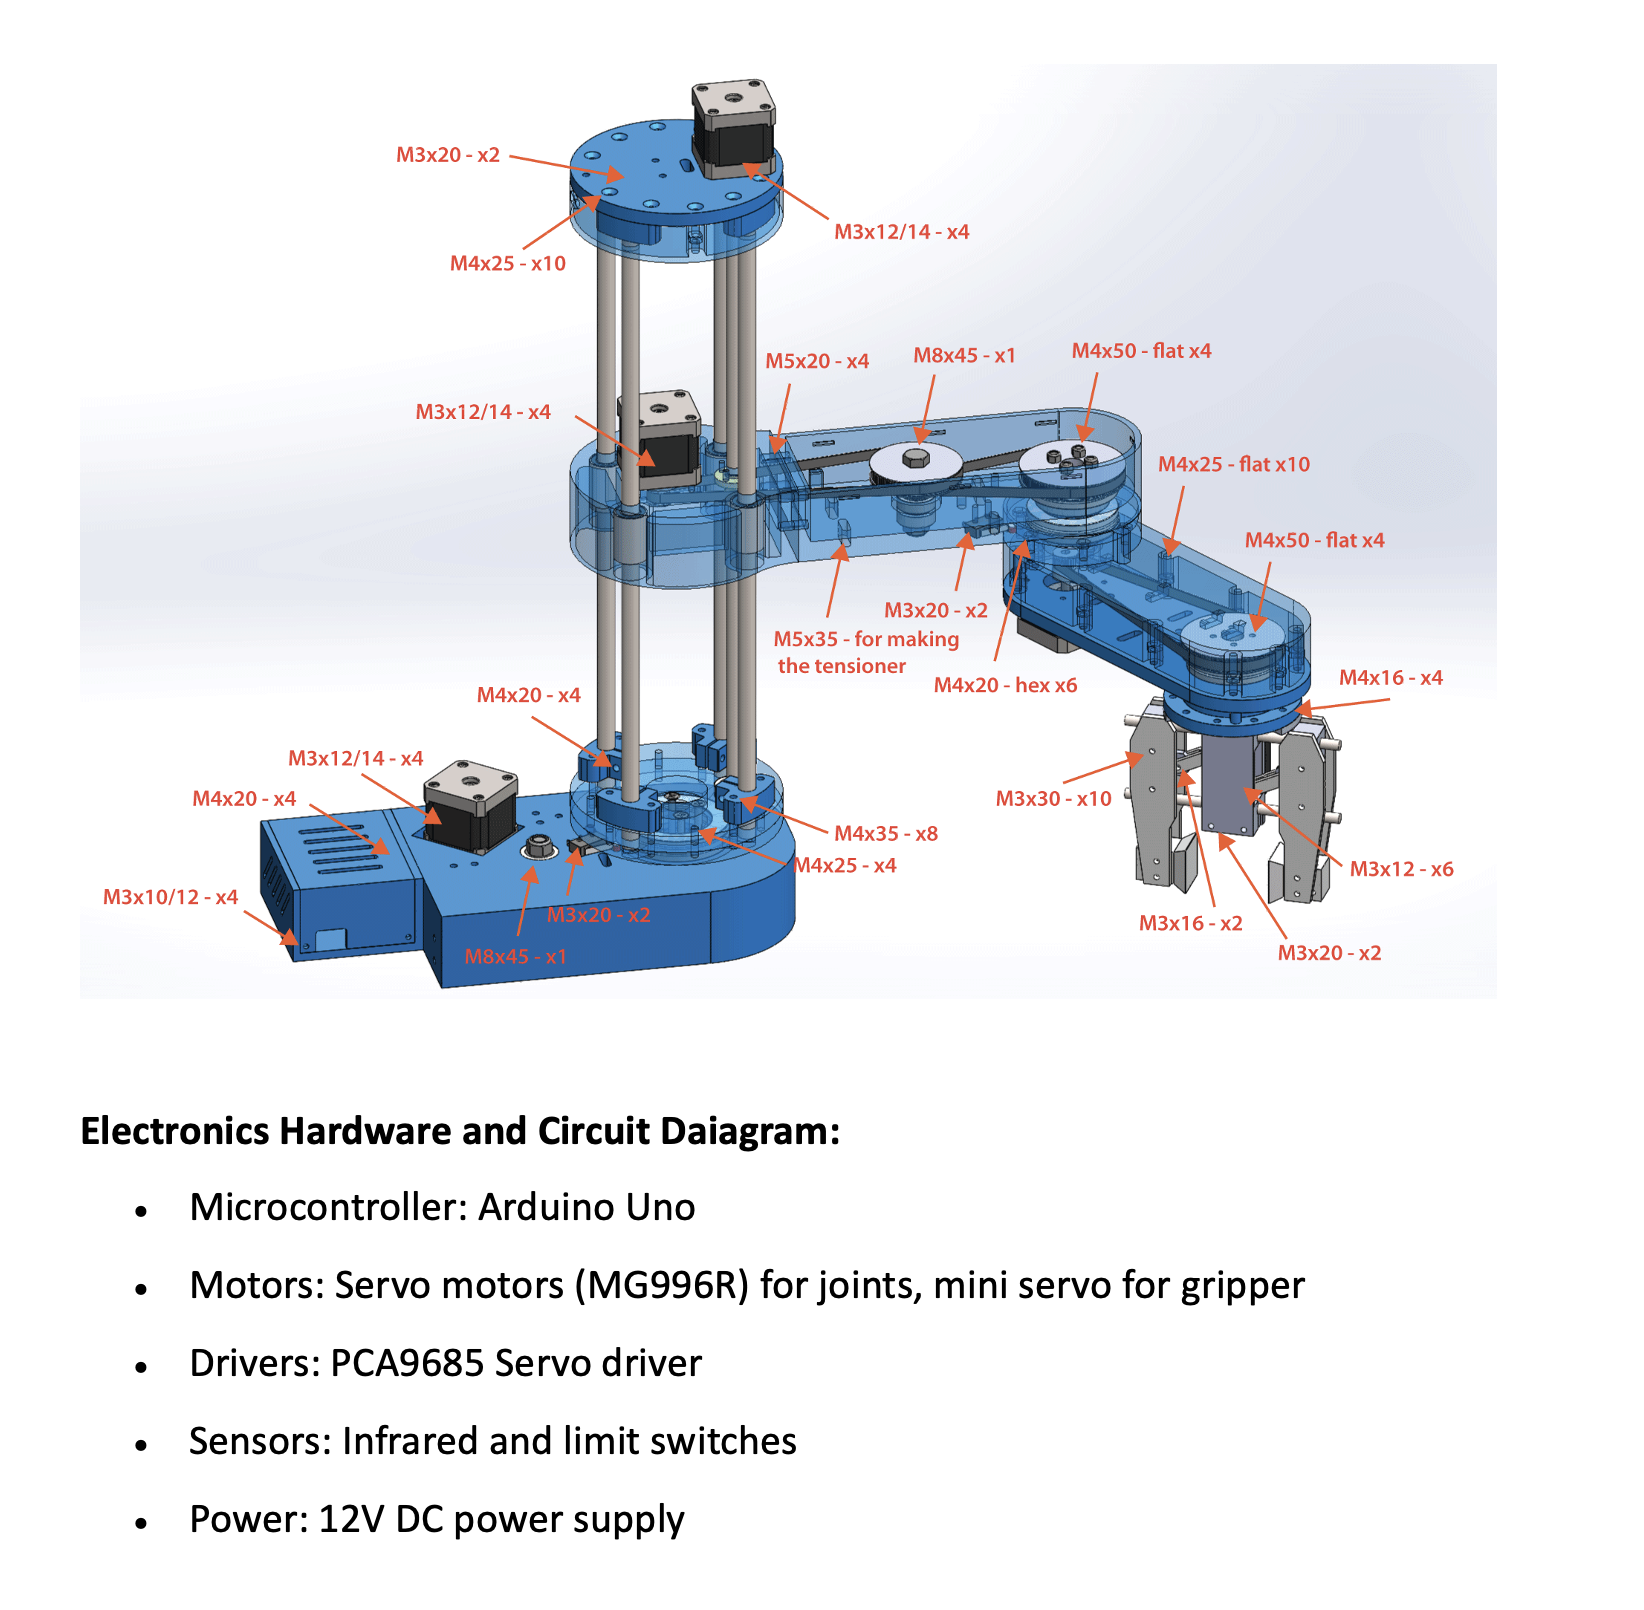
This project presents the design and implementation of a Selective Compliance Assembly Robot Arm (SCARA) optimized for automated pick-and-place operations. Featuring two horizontal revolute joints and a vertical prismatic axis, the manipulator achieves high precision, fast cycle times, and structural rigidity within a defined workspace. Microcontroller-based hardware integrates stepper motors, feedback encoders, and an end-effector gripper, while custom kinematic algorithms drive precise trajectory planning. Experimental testing confirms high repeatability, position accuracy, and efficient payload handling. The implemented SCARA system offers a scalable, cost-effective solution for industrial automation, streamlining tasks like component sorting, assembly line transfer, and automated packaging.
الكلمات المفتاحية
SCARA robot
Arduino
raspberry PI
Project Poster
Project students